Projects
2026
- FieldAI Humanoid ProjectDemos and Deployments
Training humanoid whole-body loco-manipulation for real-world use cases, and building safe policy deployment in uncertain environments.
2025
2024
-
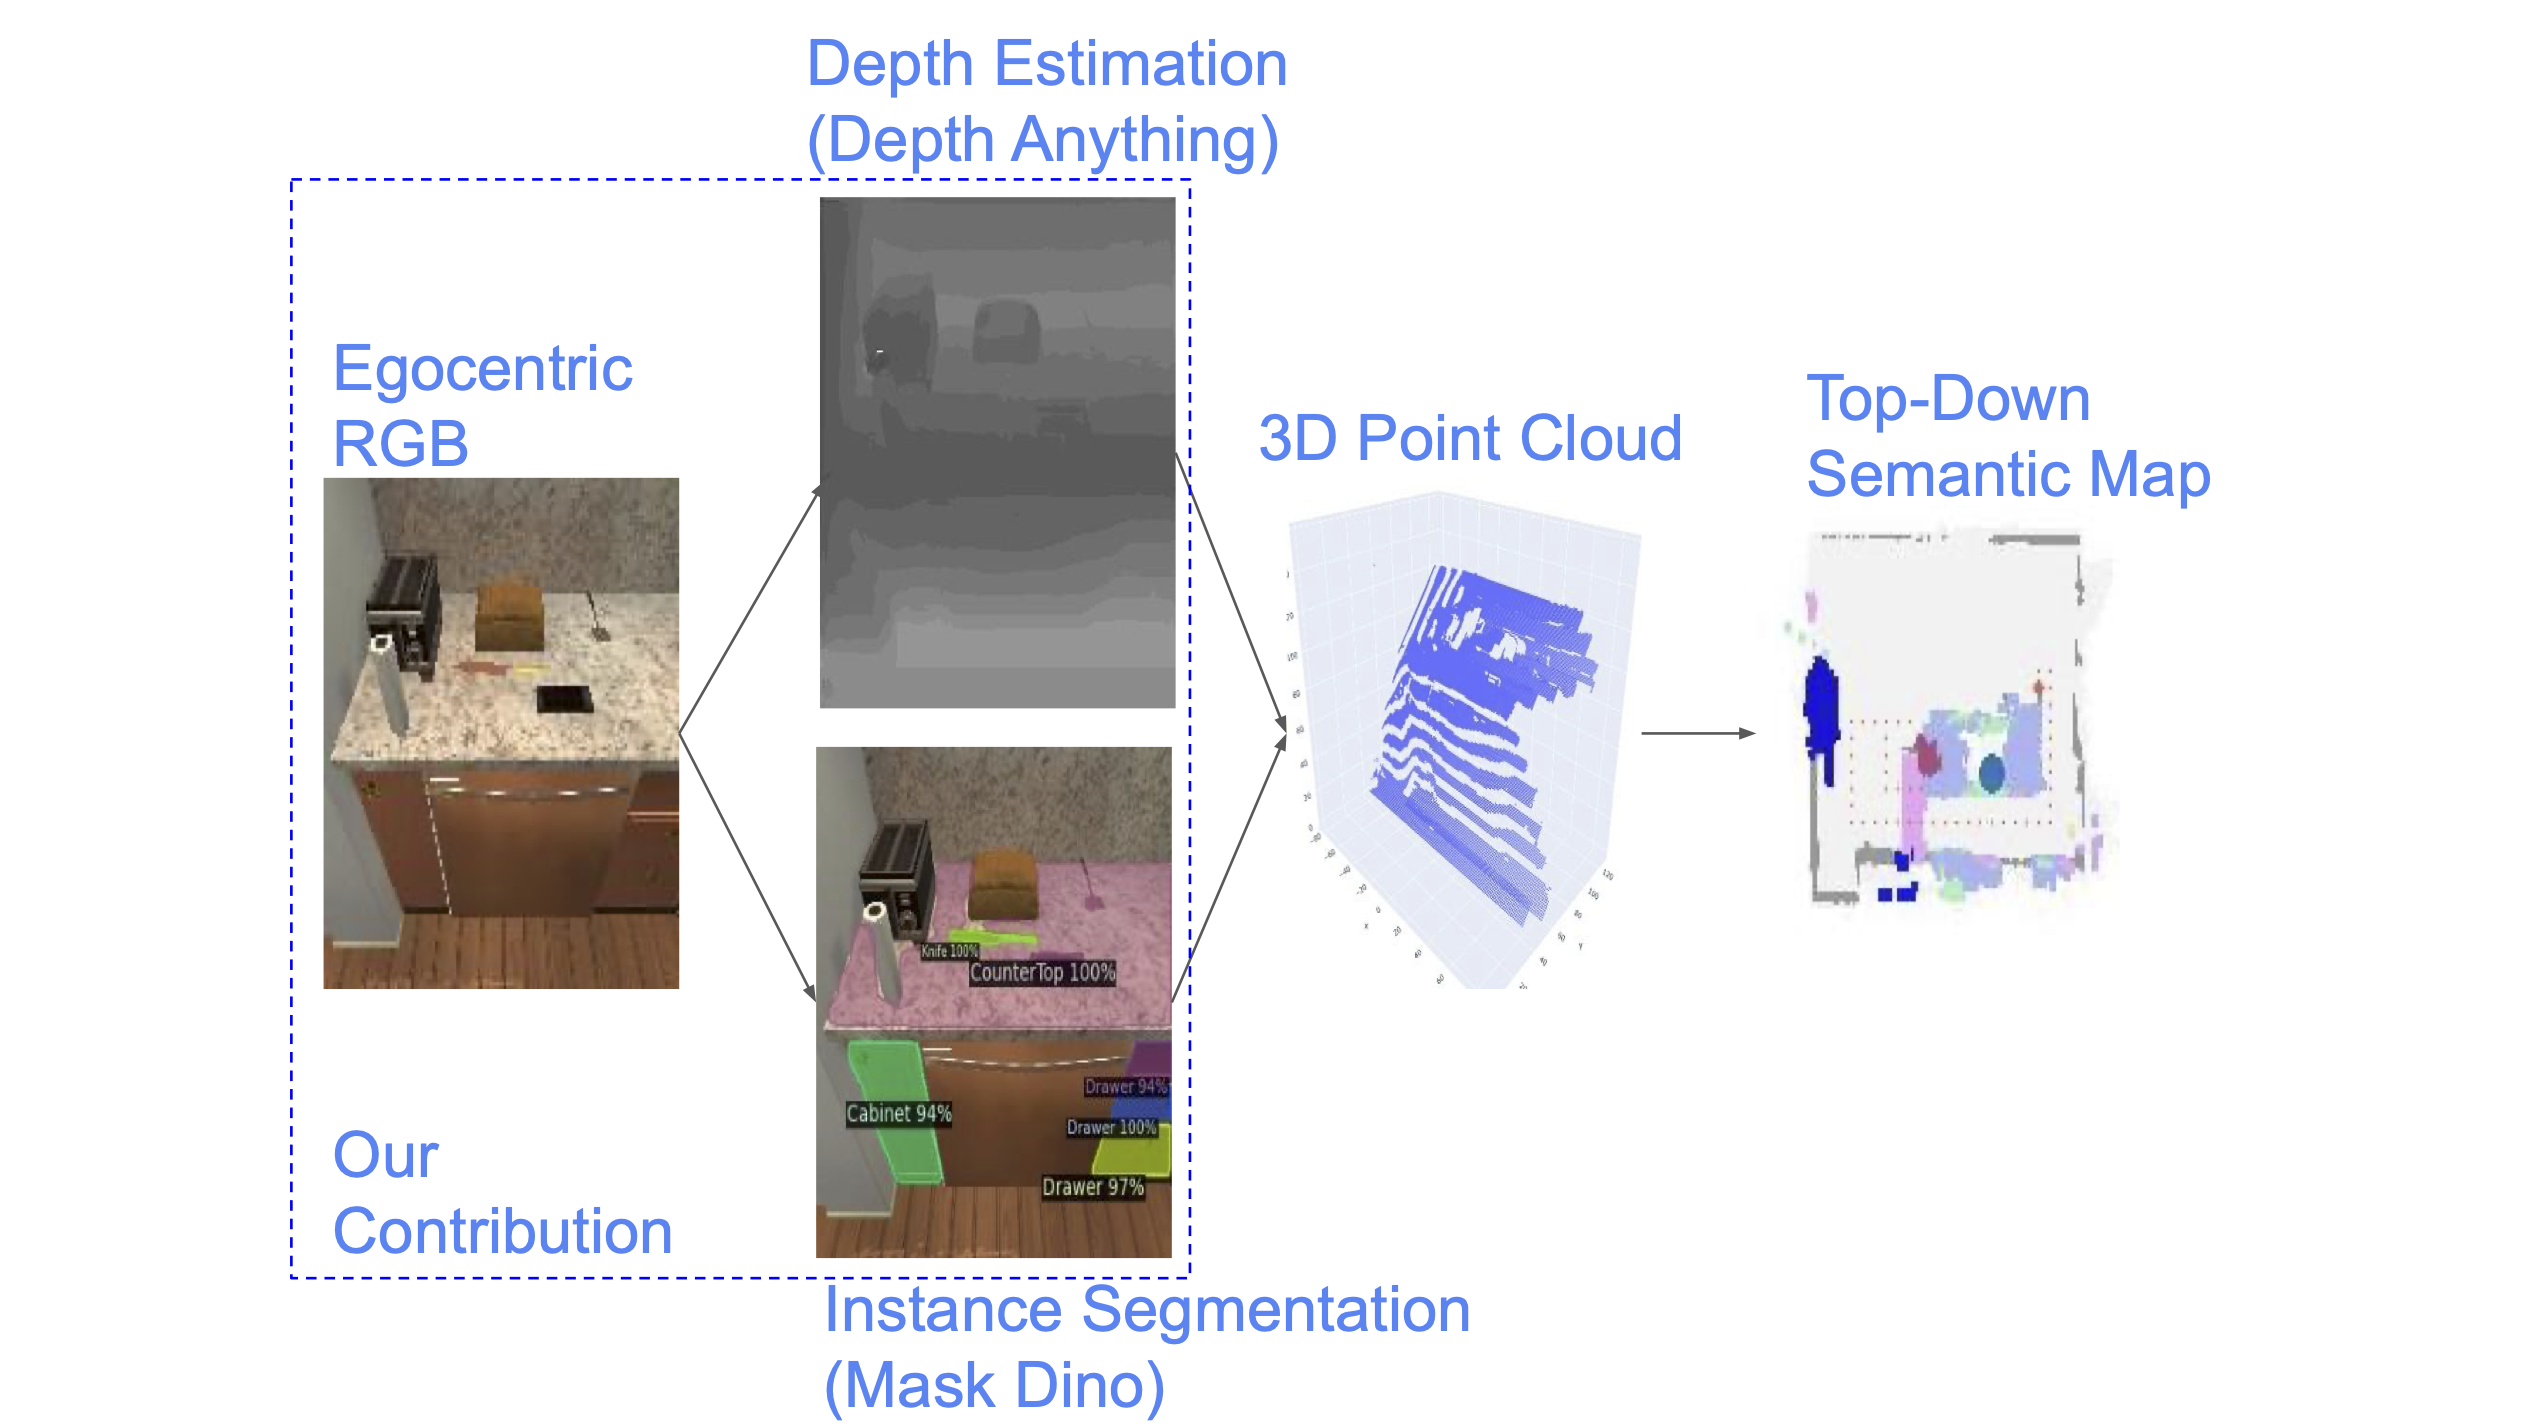 Multimodal Analysis of Embodied Instruction Following on ALFREDCourse Project: CMU 11-777 Multimodal Machine Learning
Evaluating how updated foundation models like DepthAnything and MaskDINO affect embodied instruction following on ALFRED.
-
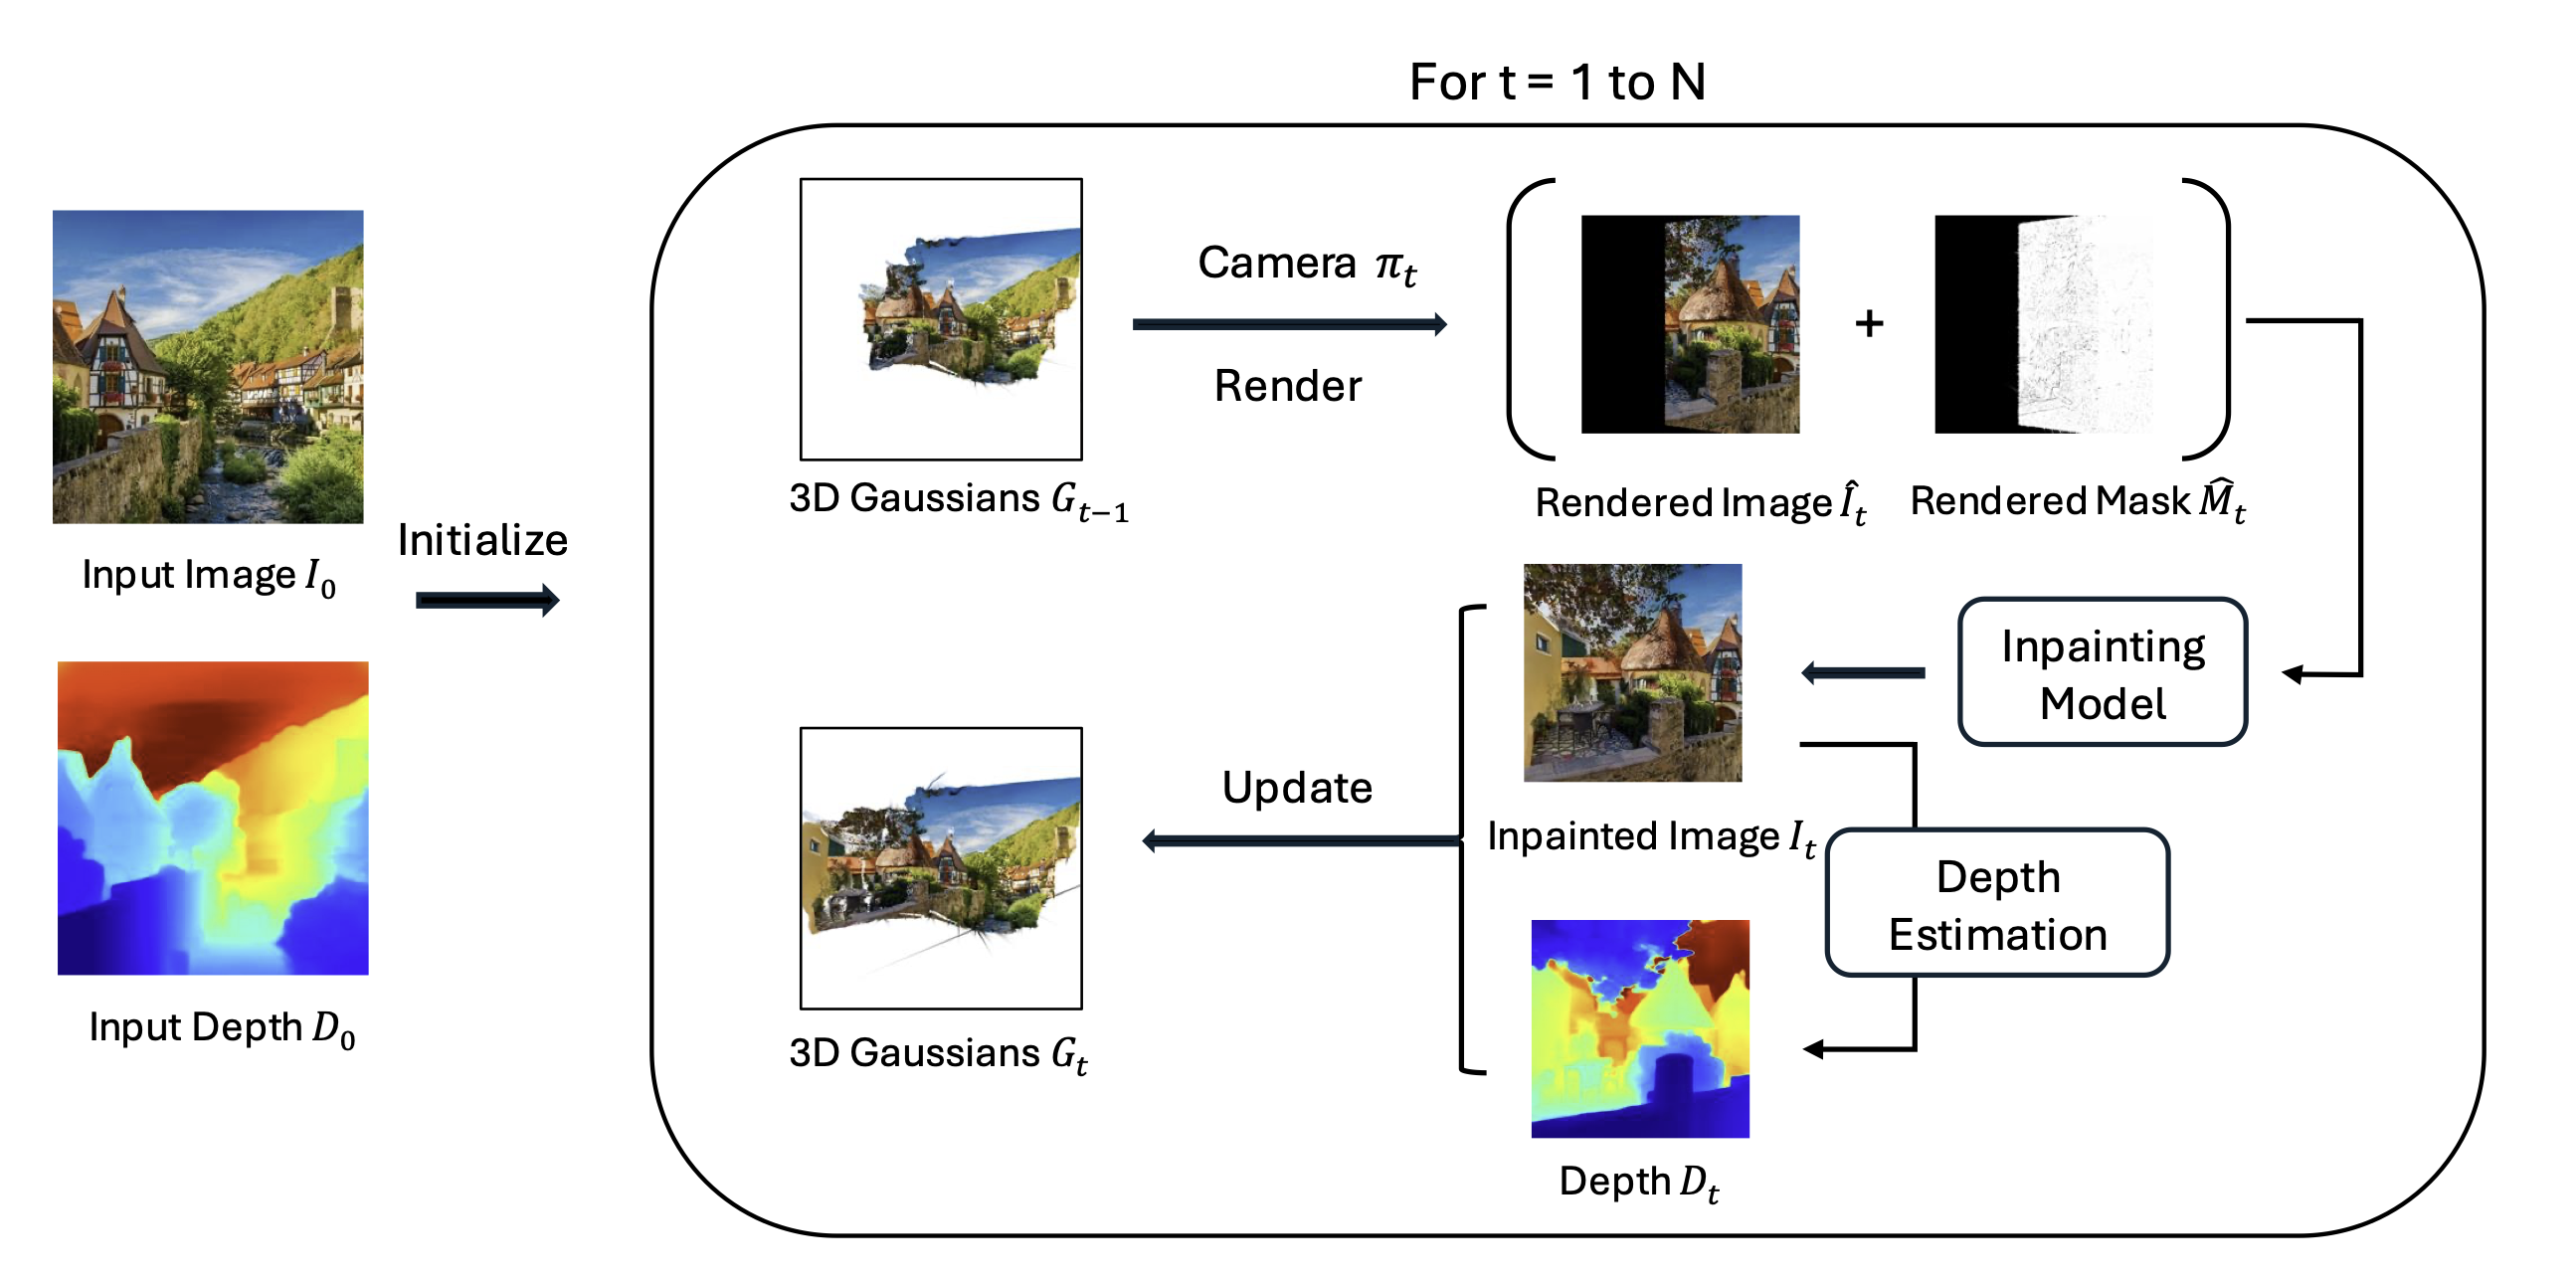 SceneGaussian: Unconstrained Generation of 3D Gaussian Splatting ScenesCourse Project: CMU 16-825 Learning for 3D Vision
Generating consistent 3D Gaussian splatting scenes from a single image along an arbitrary camera trajectory.
-
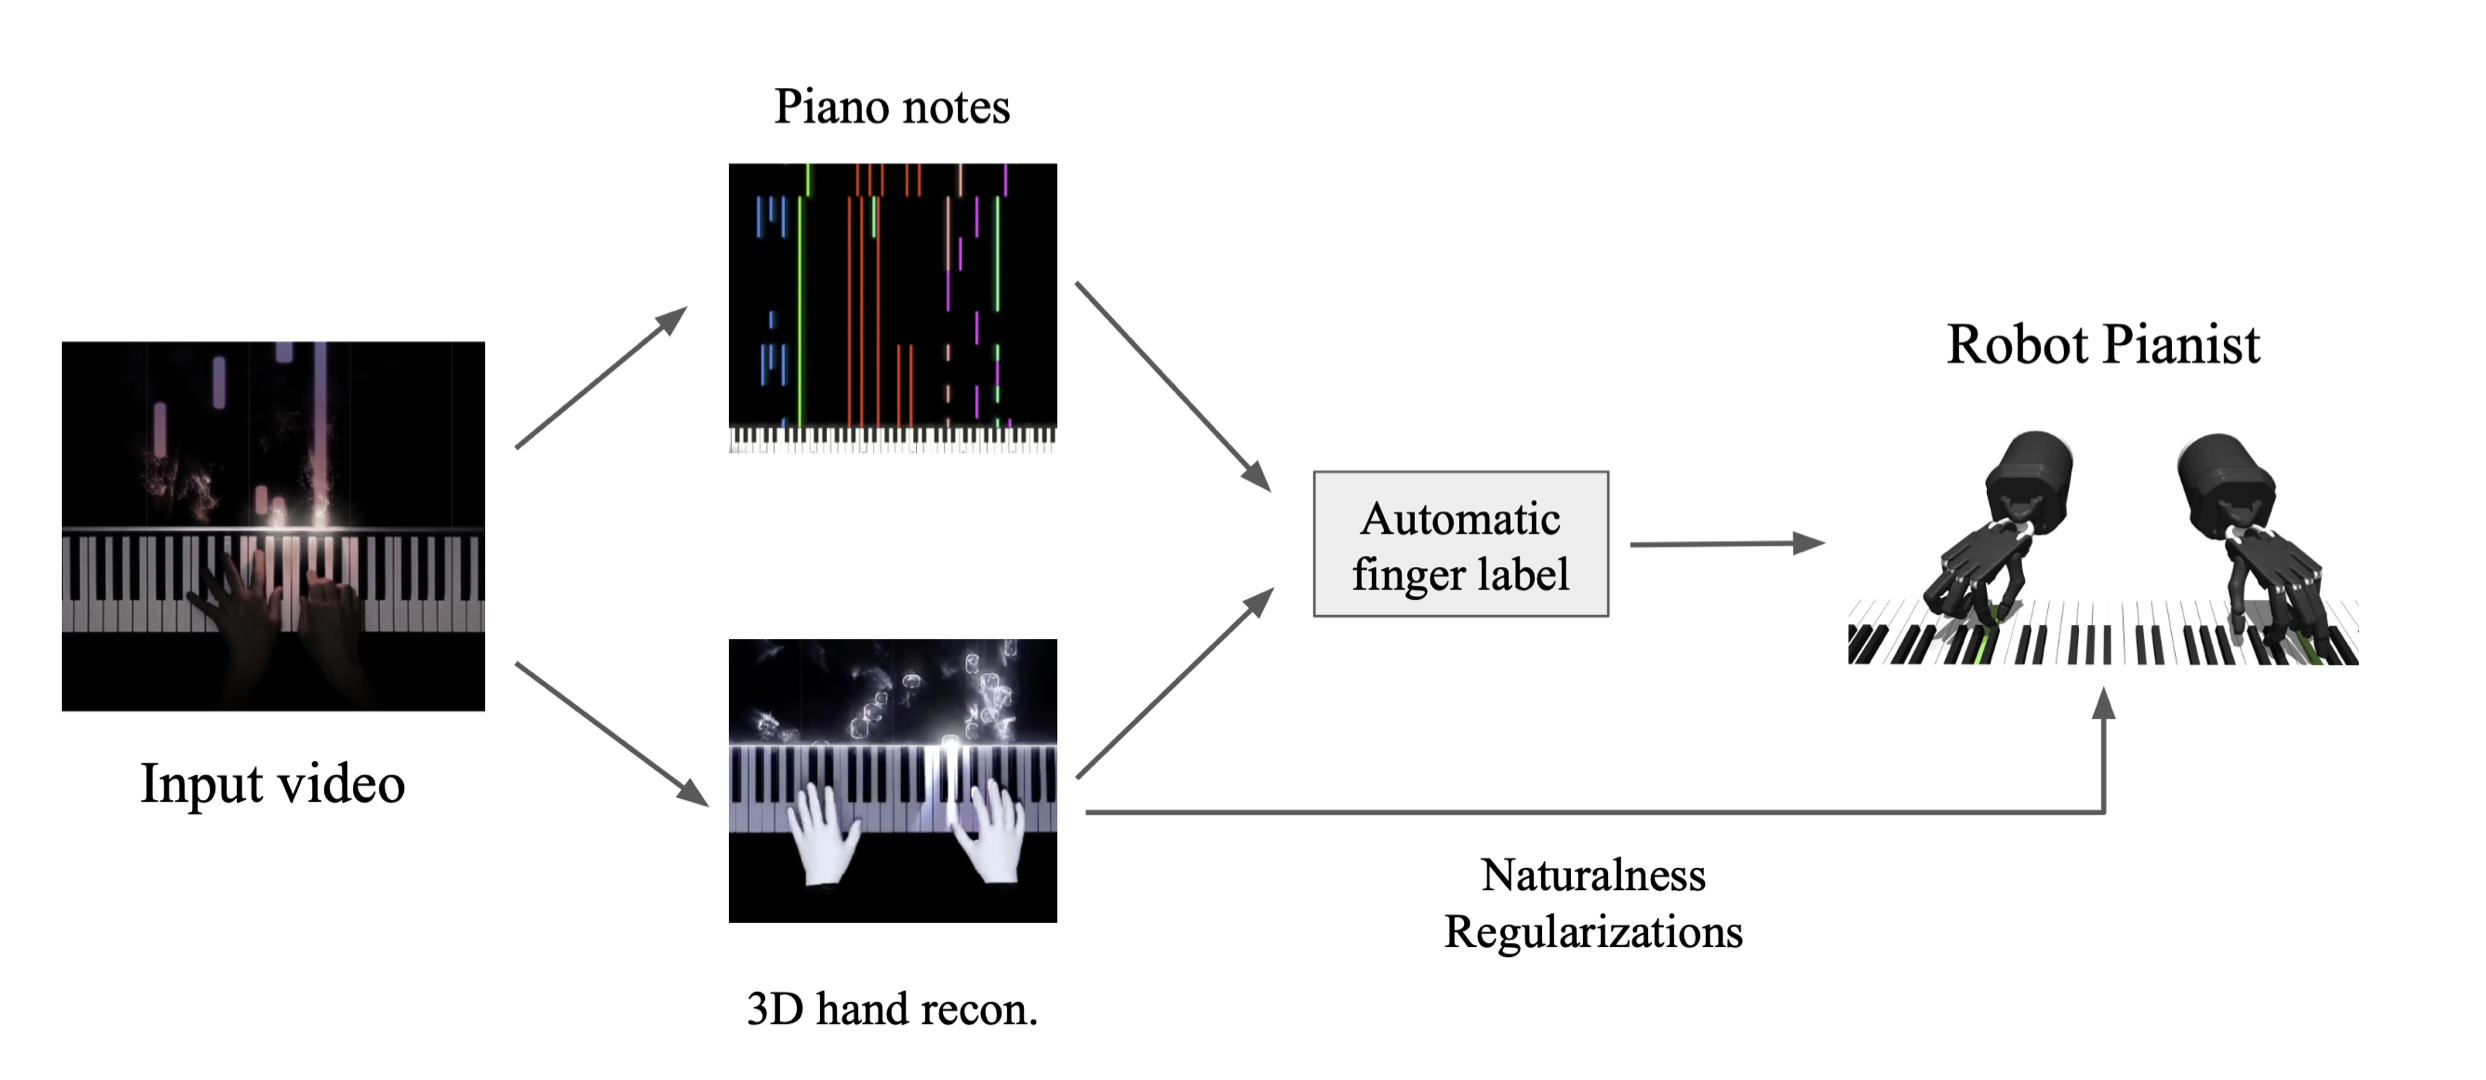 Natural Dexterous Piano Playing at Scale With Video Hand PriorsCourse Project: CMU 16-831 Introduction to Robot Learning
Learning robotic piano playing from YouTube videos, using hand pose estimation and music transcription to label fingering.


2023
-
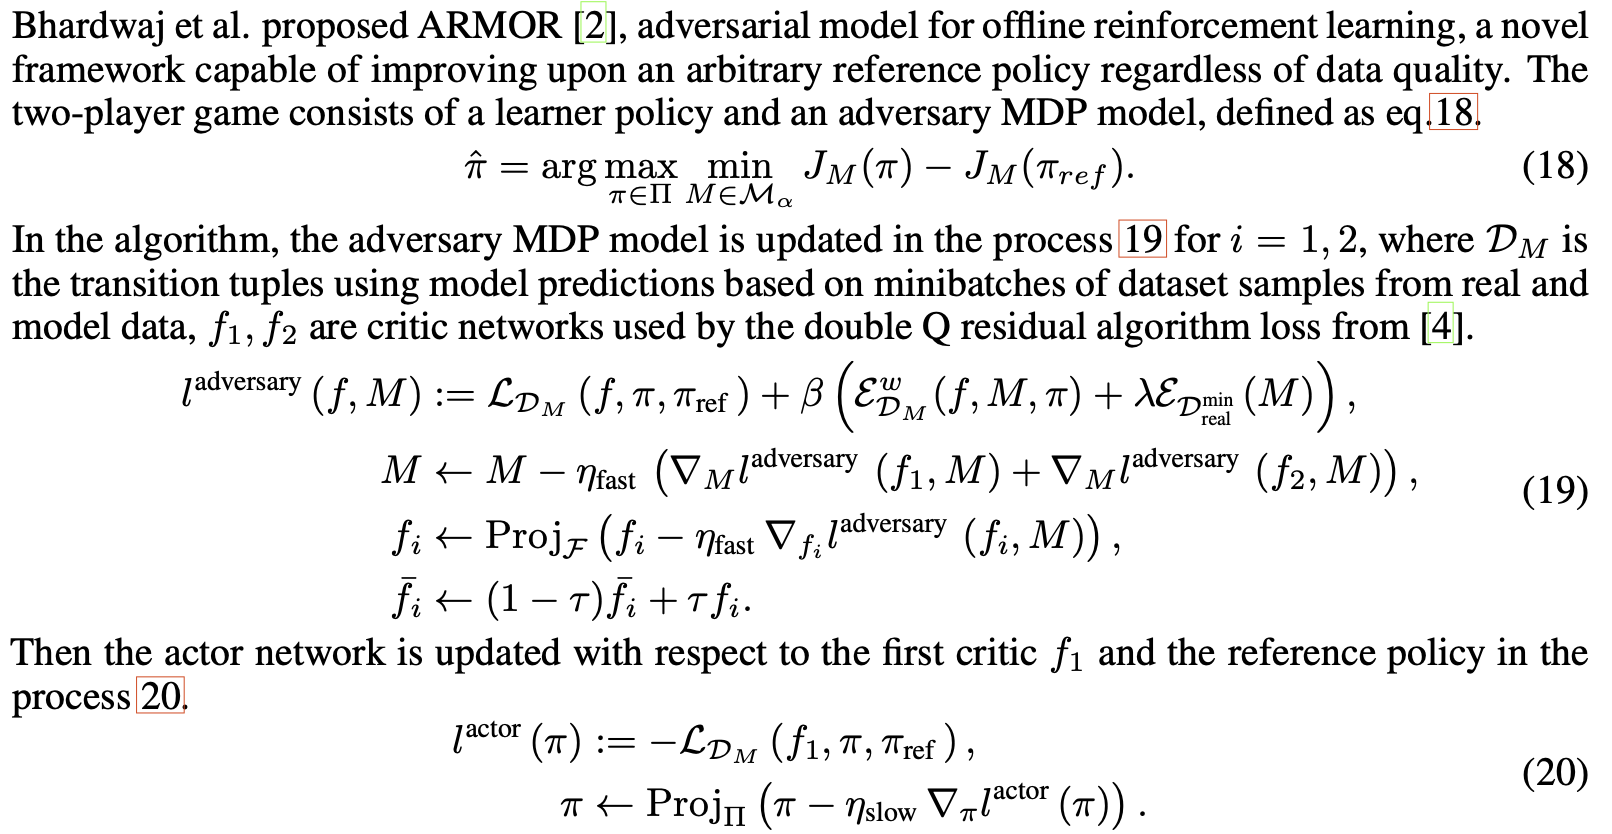 A Survey on Offline Model-Based Reinforcement LearningCourse Project: CMU 18-813B Foundations of Reinforcement Learning
Surveying recent offline model-based reinforcement learning methods and how they address distributional shift.

2022
-
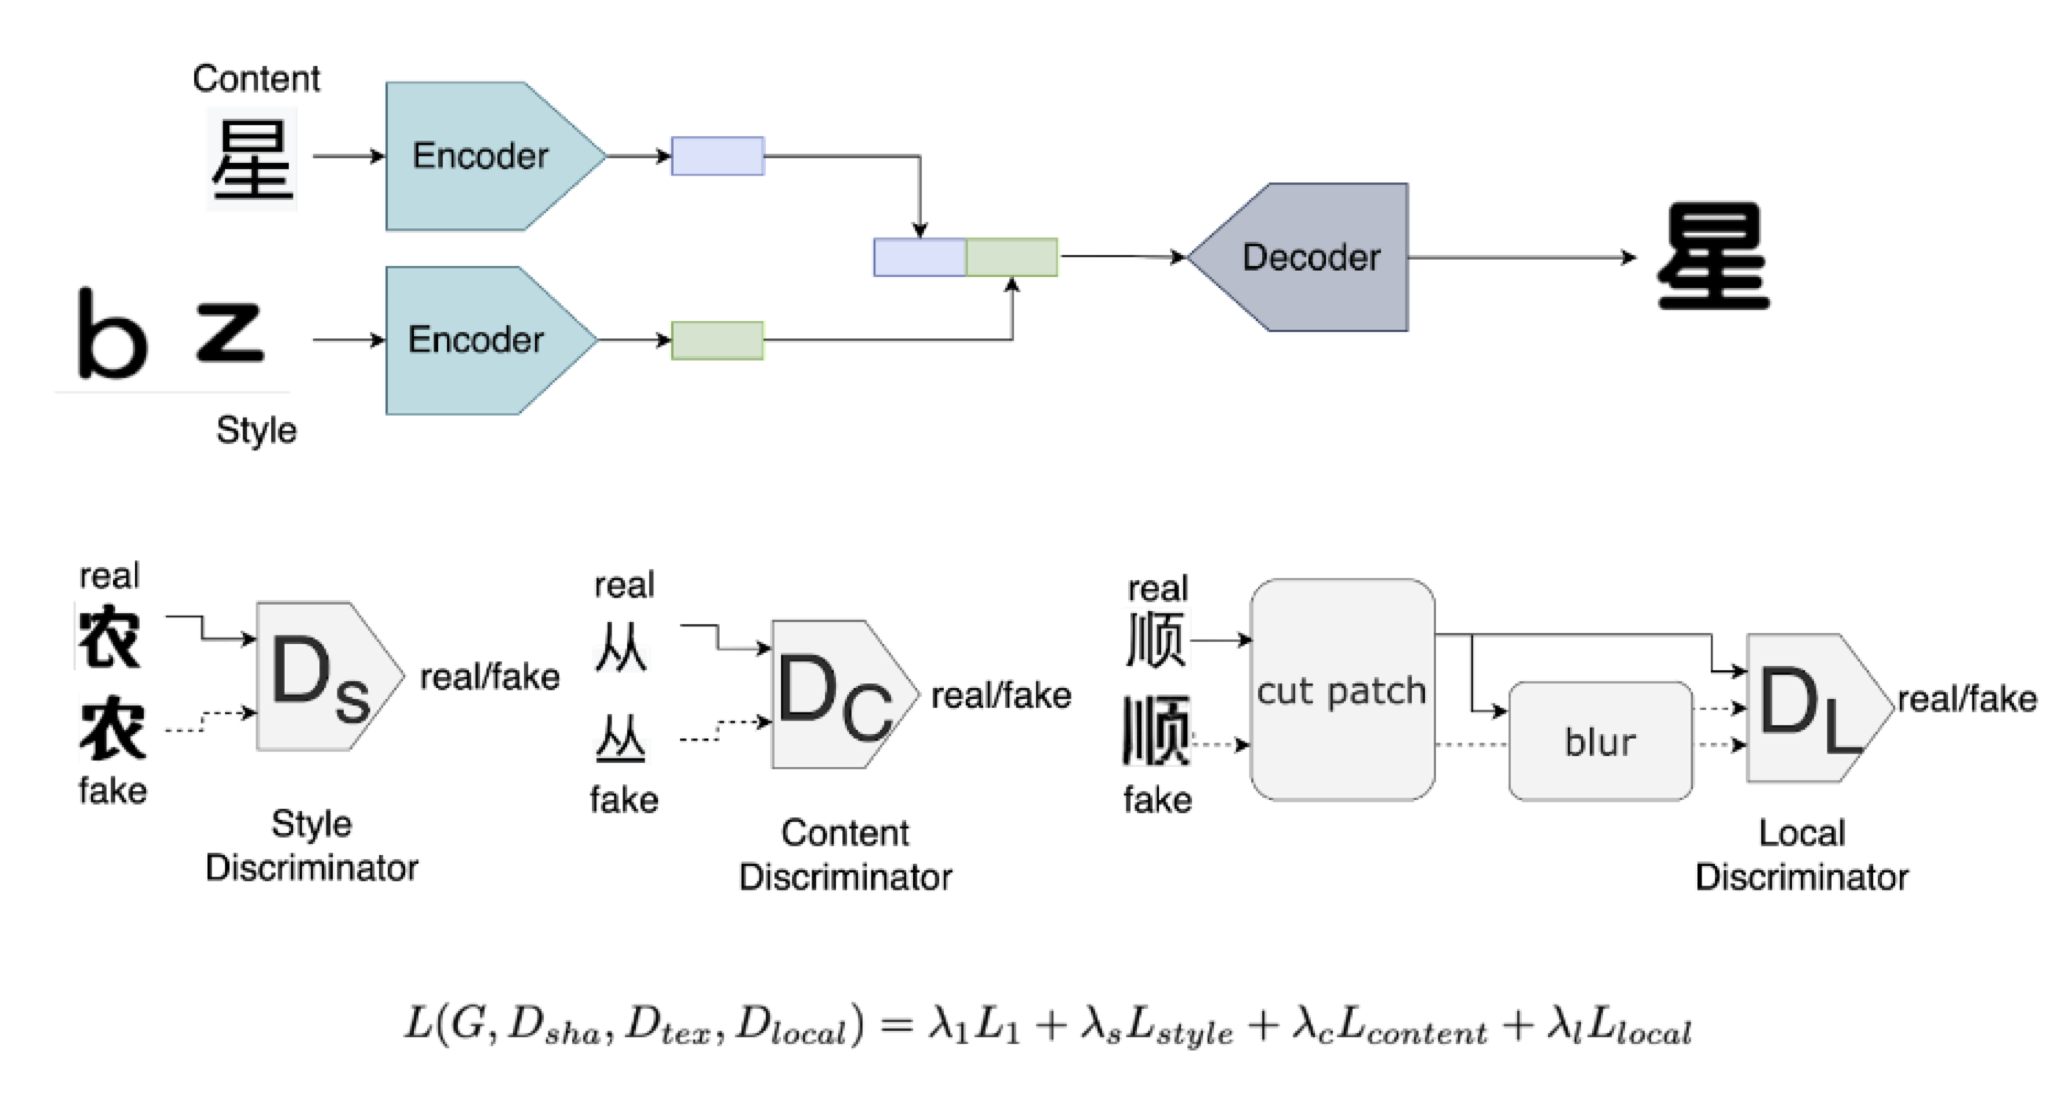 GAS-NeXt: Few-Shot Cross-Lingual Font GeneratorCourse Project: CMU 11-785 Introduction to Deep Learning
Few-shot cross-lingual font generation, translating font styles across languages such as English to Chinese.
-
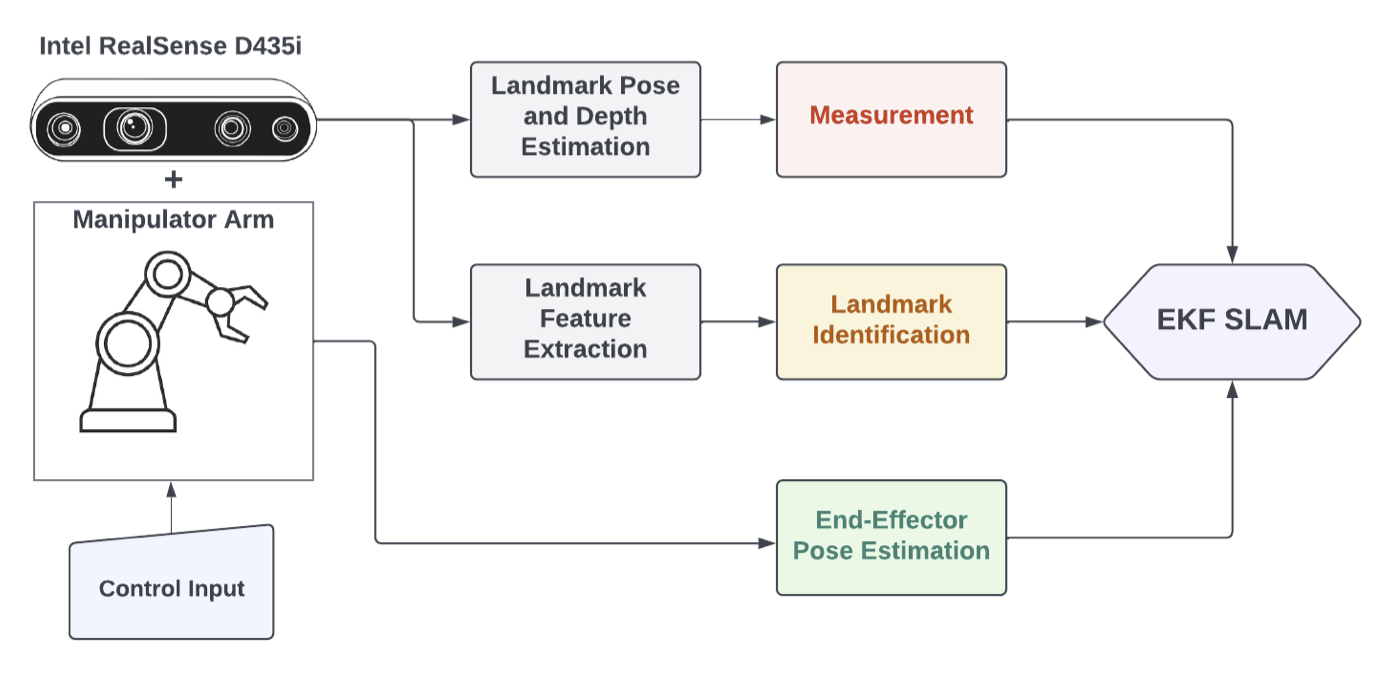 Automatic Eye-in-Hand Calibration using EKFCourse Project: CMU 16-833 Robot Localization and Mapping
Automatically calibrating the camera-to-end-effector transform of an eye-in-hand robot arm with EKF-based SLAM.

